

DBSCAN Clustering Explainer
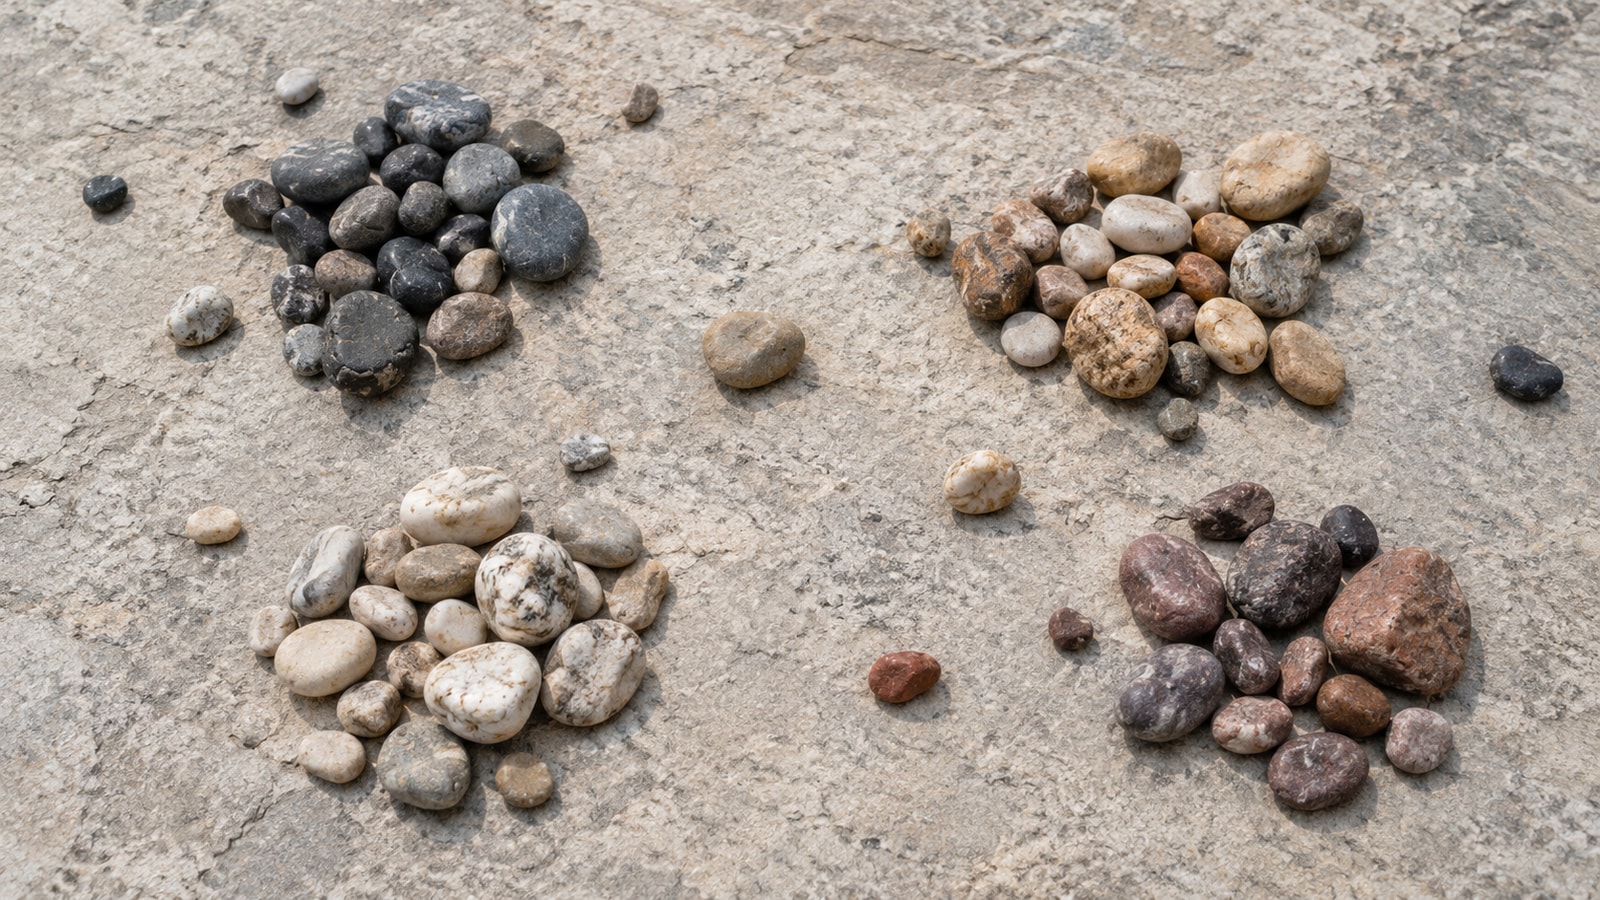
Density-Based Spatial Clustering of Applications with Noise, or DBSCAN, groups observations that belong to sufficiently dense neighborhoods. It can discover irregularly shaped clusters and label sparse observations as noise.
The method uses a neighborhood radius and a minimum number of nearby samples. Core points meet the density requirement, border points connect to a core neighborhood, and noise points meet neither condition.
Unlike k-means, DBSCAN does not require a cluster count in advance and does not assume spherical groups. It can be effective when meaningful groups are separated by low-density regions.
One global density setting can struggle when clusters have very different densities. Results also depend on feature scaling, distance metric, dimensionality, and parameter selection, so domain knowledge and neighborhood diagnostics remain important.
DBSCAN forms clusters from dense neighborhoods and marks isolated observations as noise without requiring a cluster count in advance.
Key terms include density-based clustering, neighborhood radius, minimum samples, core point, border point, noise point, distance metric and outlier.
Core points have enough nearby observations to support a dense region.
Border points attach to a core region, while sufficiently isolated observations remain labeled as noise.
DBSCAN works best when clusters share a meaningful neighborhood scale and are separated by sparse space.
Scaling and variable densities can change which points connect, fragment, or disappear into noise.
Explore more "Explainers"
Discover additional explainers across politics, science, business, technology, and other fields. Each explainer breaks down a complex idea into clear, everyday language—helping you better understand how major concepts, systems, and debates shape the world around us.